LULI

Lab for Urban Low-altitude Intelligence

School of Future Science and Engineering, Soochow University

Located at the Future Campus of Soochow University in Suzhou, the LULI Lab focuses on cutting-edge interdisciplinary research bridging artificial intelligence and aeronautics. It places strong emphasis on multimodal perception and embodied intelligent navigation in physical environments. By integrating physics-driven data engines, numerical simulation, deep learning, and vision-language/ large language models (VLMs/LLMs), the lab aims to advance quiet and sustainable low-altitude mobility in complex urban airspace, while exploring fundamental science for autonomous decision-making and interaction of UAVs and robots in unknown, challenging environments.

We are currently recruiting Master's and Doctoral students for enrollment in 2026/2027. If you are a diligent student who enjoys embodied intelligence, UAV perception and practical robotic applications, you are highly welcome to join LULI and grow together with us!

Path Planning Noise Assessment Vision-Language Navigation Embodied AI

📰 News

People

Faculty & Guest Faculty

Qichen Tan
Qichen Tan
Assoc. Prof.

Ph.D. Students

Xin Liu
Xin Liu
2023-
Embodied AI
Tao Li
Tao Li
2024-
Embodied AI
Xu Han
Xu Han
2025-
Embodied AI

Master’s Students

Haosen Li
Haosen Li
2025-
Multimodal-based Trajectory Tracking of UAV
Yimin Tang
Yimin Tang
2026-
Vision-Language-Navigation of UAV
Jinxing Li
Jinxing Li
2026-
Embodied AI
Zhikun Li
Zhikun Li
2026-
Multimodal perception of UAV
Yi Lin
Yi Lin
2026-
Computer Vision & Environment Perception of UAV

Undergraduate Students
Ziyan Ding
Ziyan Ding
2023-
LLM for UAV flight planning
Kaixu Chen
Kaixu Chen
2023-
Multi-agent flight optimization of UAV

Alumni

Xin Liu
Pursuing PhD study in USTC
Research

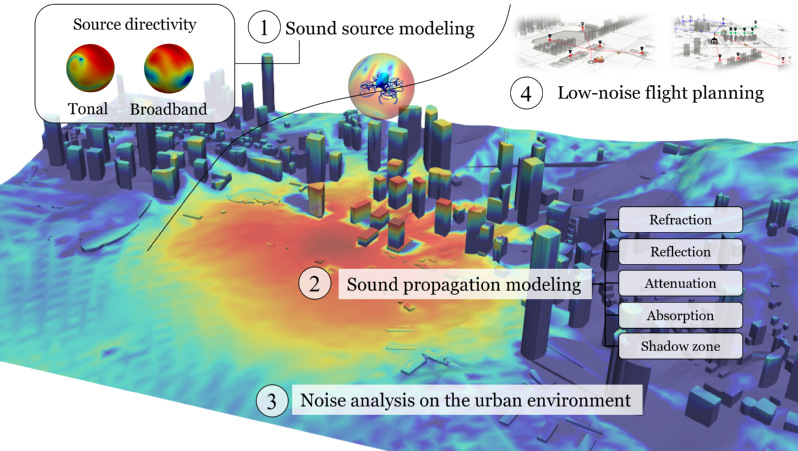
Virtual Flight and Noise Assessment Simulator for Low-Altitude Aircraft

Virtual Flight and Noise Assessment Simulator for Low-Altitude Aircraft

  • Noise modeling through experiments, simulations, and semi-empirical methods.
  • Prediction of noise directivity, intensity, and characteristic frequencies.
  • Visualization and auralization of environmental noise.
Noise-Aware Flight Optimization and Sustainable Low-Altitude Mobility

Noise-Aware Flight Optimization and Sustainable Low-Altitude Mobility

  • Noise-aware path planning for single and multiple UAVs.
  • Intelligent coordination of UAV fleets.
  • Optimization of urban vertiport placement and drone delivery logistics.
UAV Trajectory Tracking Using Spatial Acoustics

UAV Trajectory Tracking Using Spatial Acoustics

  • Analysis of UAV rotor noise characteristics.
  • Acoustic tracking through signal processing and machine learning.
  • Accurate non-line-of-sight tracking in complex background noise.
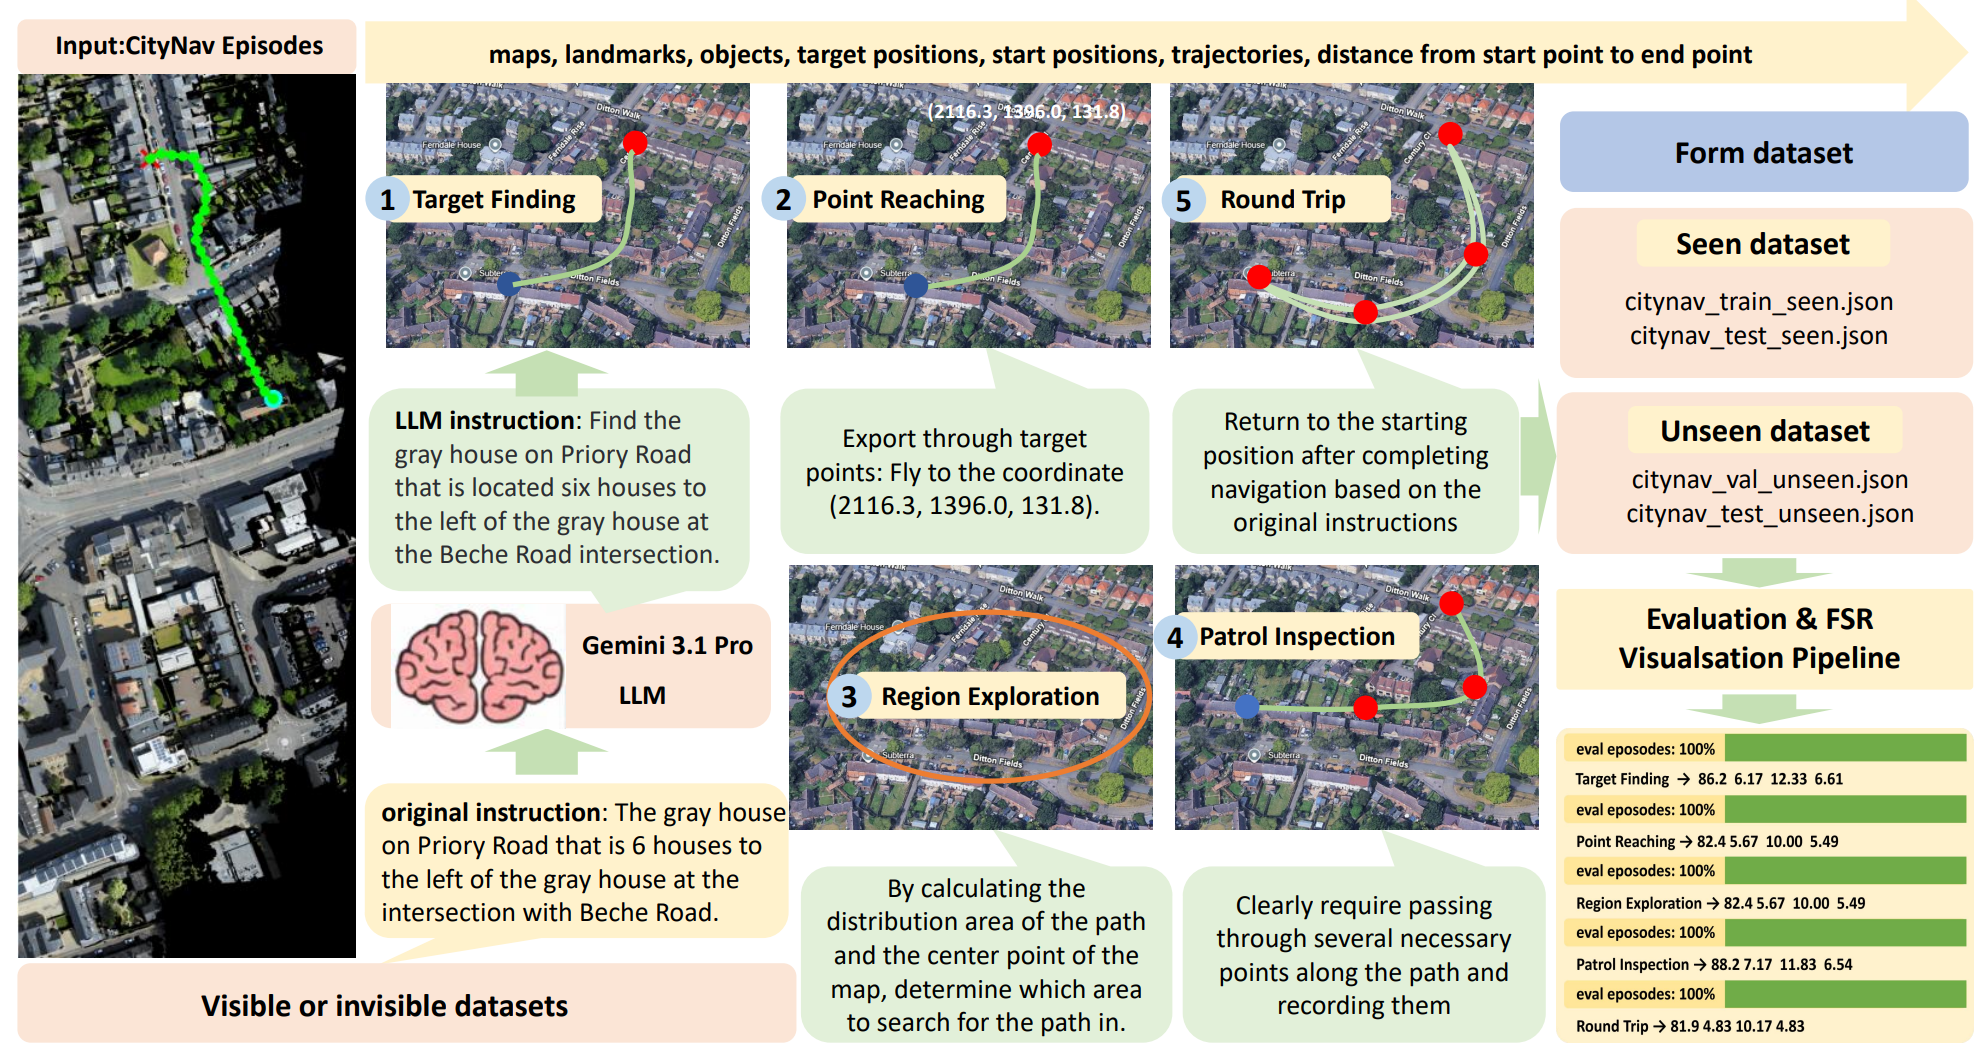
UAV Vision-Language Navigation with Open-Ended Instructions

UAV Vision-Language Navigation with Open-Ended Instructions

  • Perception and reasoning in complex, unknown 3D environments.
  • Understanding of open-ended natural-language instructions.
  • Autonomous navigation and interaction for UAVs and robots.

Publications

Selected Journal Papers

Paper illustration

Enhancing sustainable urban air transportation: Low-noise UAS flight planning using noise assessment simulator

Aerospace Science and Technology · 2024

Urban Air Mobility; UAS Flight Planning; Noise Assessment Simulator

Paper illustration

Low-Noise flight path planning of drones based on a virtual flight noise simulator: A vehicle routing problem

IEEE Intelligent Transportation Systems Magazine · 2024

Drone Path Planning; Vehicle Routing Problem; Virtual Flight Noise

Paper illustration

Exploring noise reduction strategies: Optimizing drone station placement for last-mile delivery

Transportation Research Part D: Transport and Environment · 2024

Last-mile Delivery; Station Placement; Noise Reduction Strategies

Paper illustration

Virtual flight simulation of delivery drone noise in the urban residential community

Transportation Research Part D: Transport and Environment · 2023

Delivery Drone; Urban Residential Community; Acoustic Simulation

Paper Image

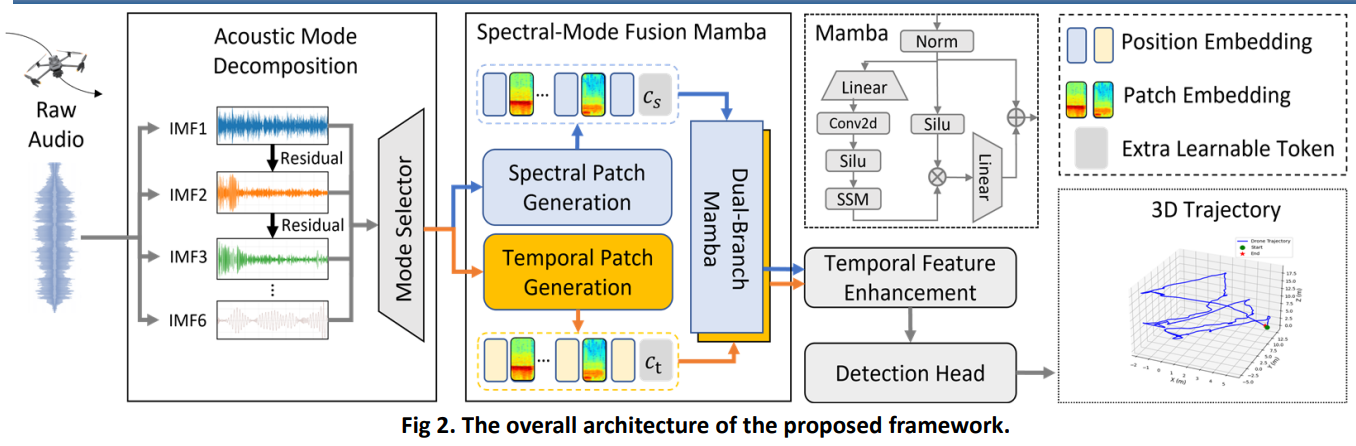
Noise-Resistant 3D Drone Trajectory Estimation via Acoustic Mode Decomposition

IEEE International Conference on Multimedia & Expo (In Press) · 2026

Spatial Acoustic Tracking; Anti-UAV

➡️ View Full Publication List on Google Scholar

Recruitment

🚀 Master’s and Doctoral Students

We welcome students with backgrounds in artificial intelligence, computer software, mathematics, mechanical engineering, or related fields who are enthusiastic about our research. Through close collaborations with leading universities in China and abroad, outstanding students may be recommended for joint training or doctoral study at leading Chinese universities, including Project 985 institutions, and renowned overseas universities. We can also provide referrals to major technology companies and other industry leaders.

💡 Undergraduate Interns

We warmly welcome undergraduate students interested in research to join our lab early. Our focus includes embodied intelligence, UAV and robot perception, vision-language navigation, and robotic manipulation skills.

Contact

Email: qctan@suda.edu.cn

Address: Future Campus, Soochow University, No. 1 Jiuyong West Road, Wujiang District, Suzhou, Jiangsu, China